Skip to content
Pi RobotikSolution for all

Robotic Machine Tending with Camera-Based Position Correction

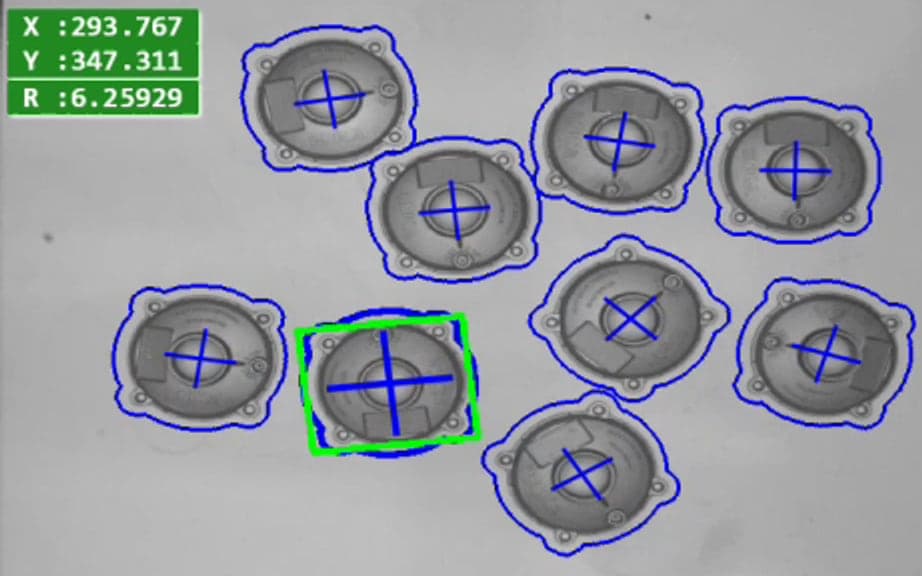
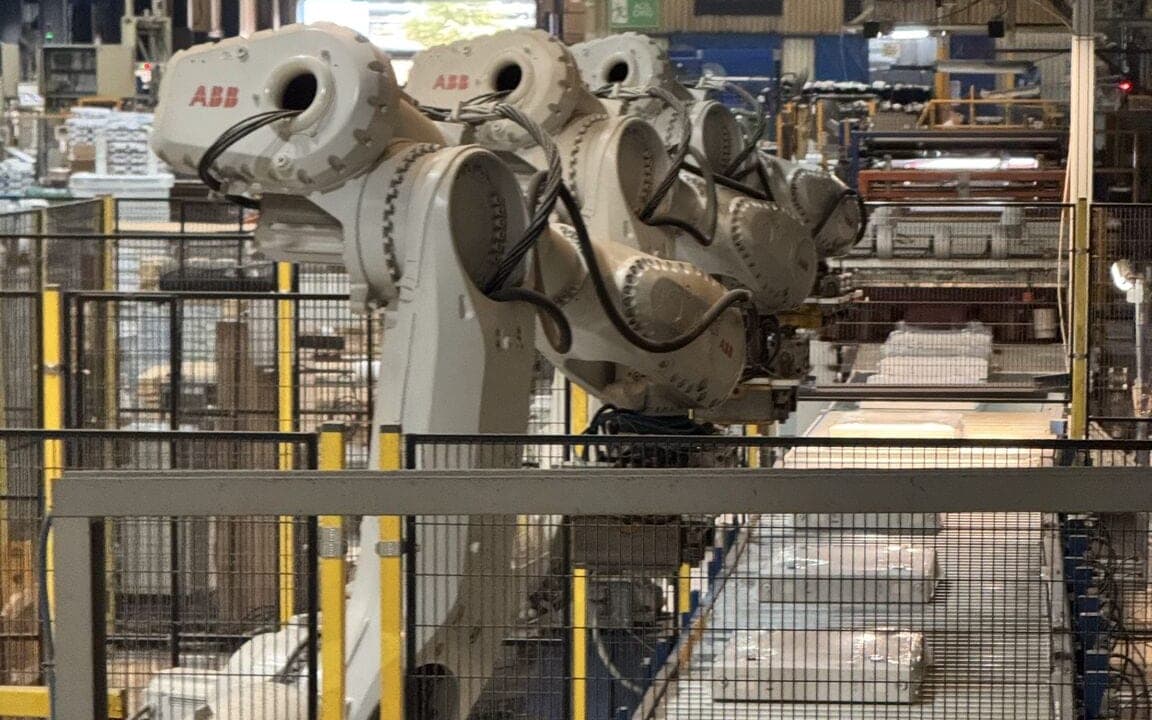
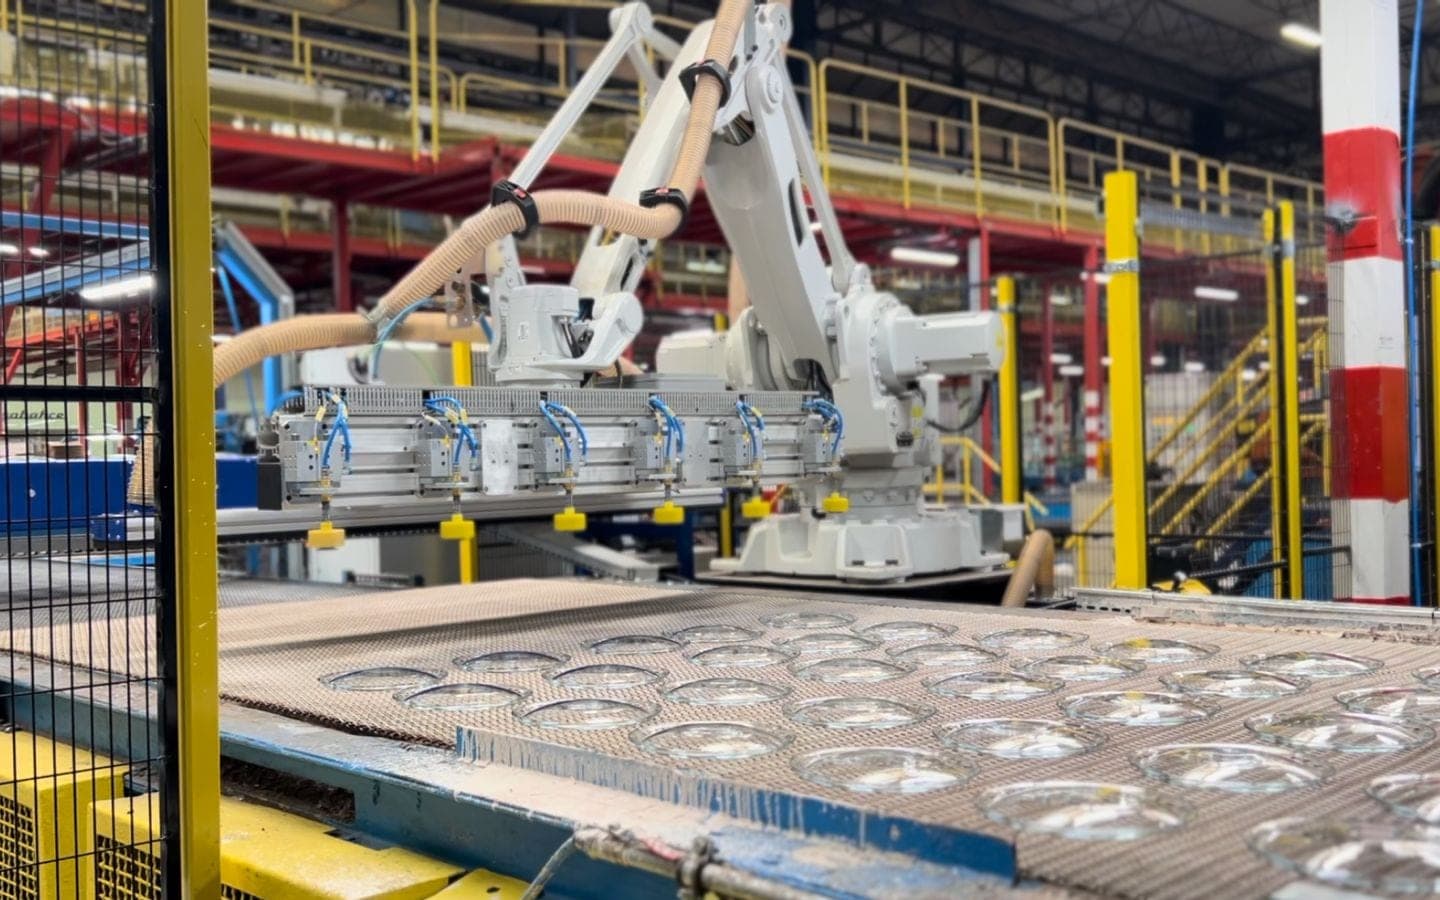
In a fenced robot cell an ABB robot picks parts and feeds them to the processing station using the position correction measured by the camera.

Project facts

Client
Arçelik
Industry
Home Appliances
Technology & equipment
ABB Robot · Machine Tending · Camera-Based Position Correction · Safety Fencing
The line in operation0:30

Our solution

The camera locates the pin and a second reference feature on the part, calculates the position deviation in X and Y in millimetres and the rotation in degrees, and sends them to the robot, which applies the correction to its motion.

The product being run is selected on screen; robot commands, logs and product settings are managed from separate tabs of the interface.
More projects

All projects