
Our solution
A camera sees the glass bowls on the belt; our machine vision software calculates the position of each bowl and sends it to the robot. The robot picks the bowls off the belt with its multi-cup vacuum gripper.
Our machine vision software locates the glass bowls on the belt; the robot picks them off the belt with its multi-cup vacuum gripper.
Project facts
A camera sees the glass bowls on the belt; our machine vision software calculates the position of each bowl and sends it to the robot. The robot picks the bowls off the belt with its multi-cup vacuum gripper.
 Handling & Tending Video
Elba · Heating
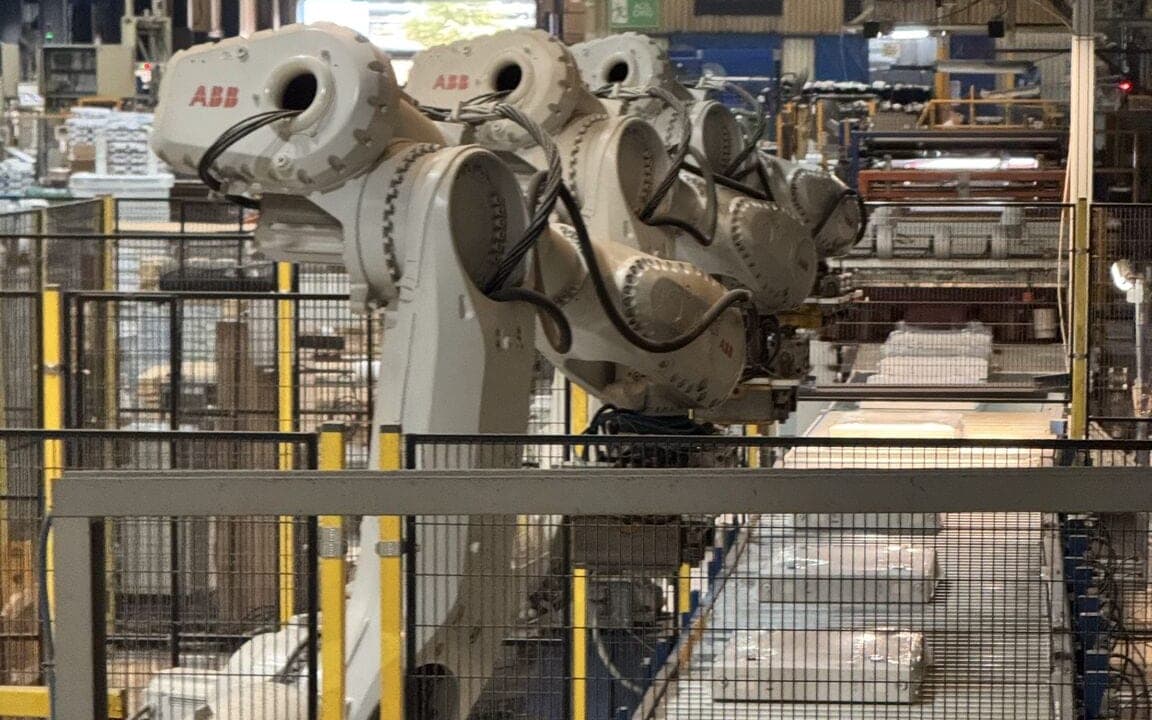
ABB robots fitted with grippers of our own design pick camera-located panel radiators off the roller conveyor and carry them.
 Machine Vision Video
ABB · Robotics & Automation
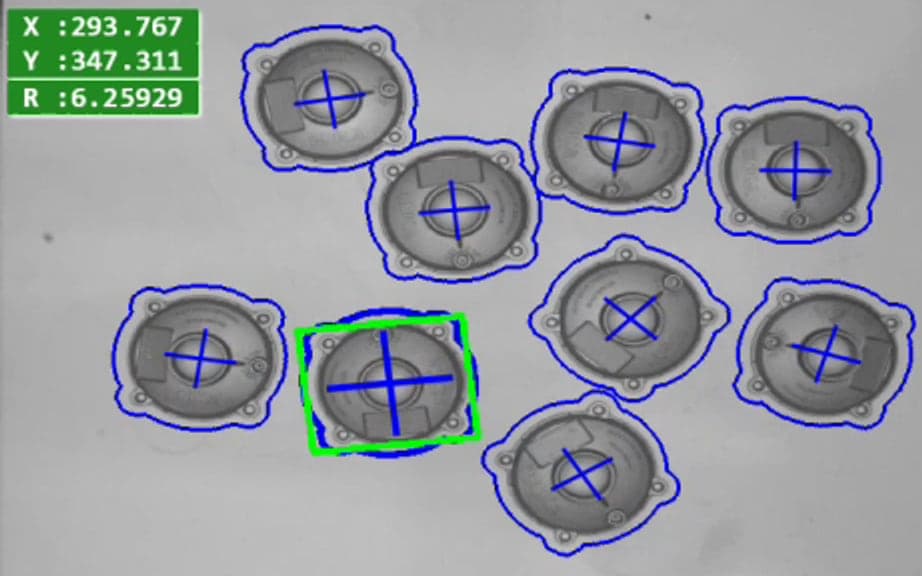
The camera finds the position and rotation of randomly placed parts; the robot uses this to pick them one by one.
 Machine Vision
Metalworking
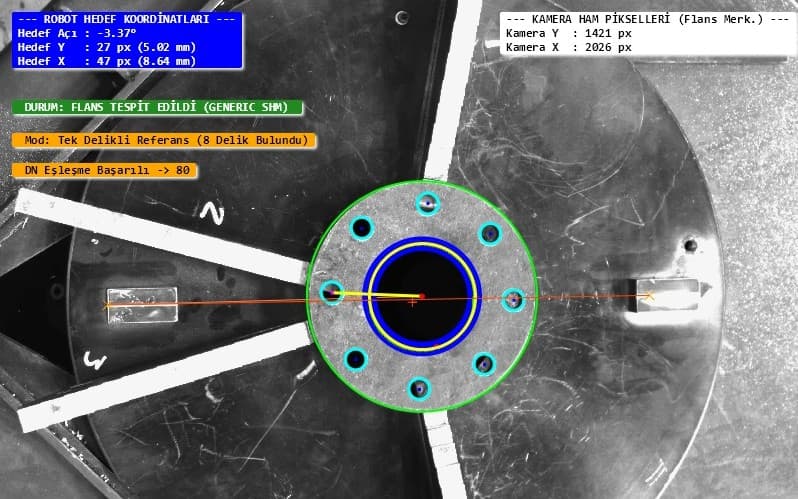
The flange type (DN50, DN80…) is identified by shape matching and its centre and bolt holes are found; the robot's target angle and position are calculated with millimetre precision.