Machine Vision
Robot Vision
Robot vision gives the robot sight: the camera finds the part and measures its position and angle, guiding ABB, KUKA, FANUC and Nachi robots to the right point.
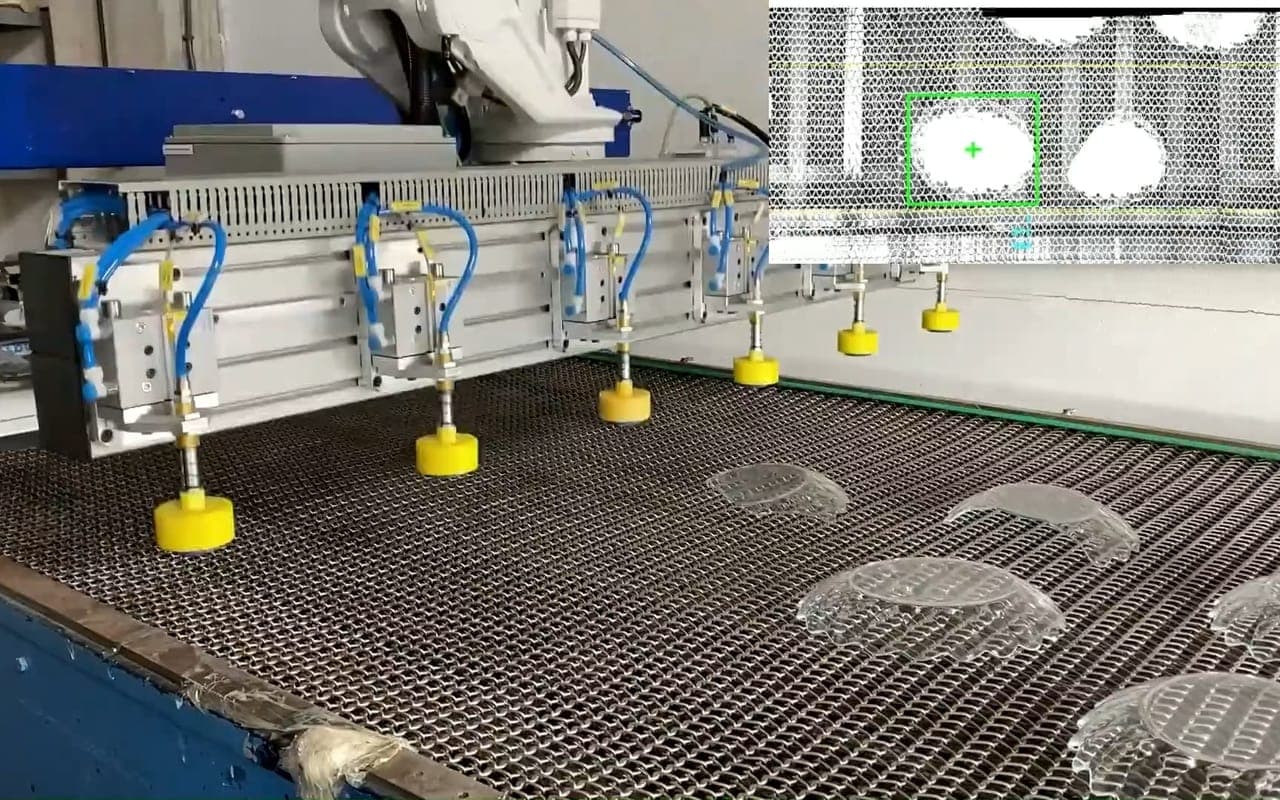
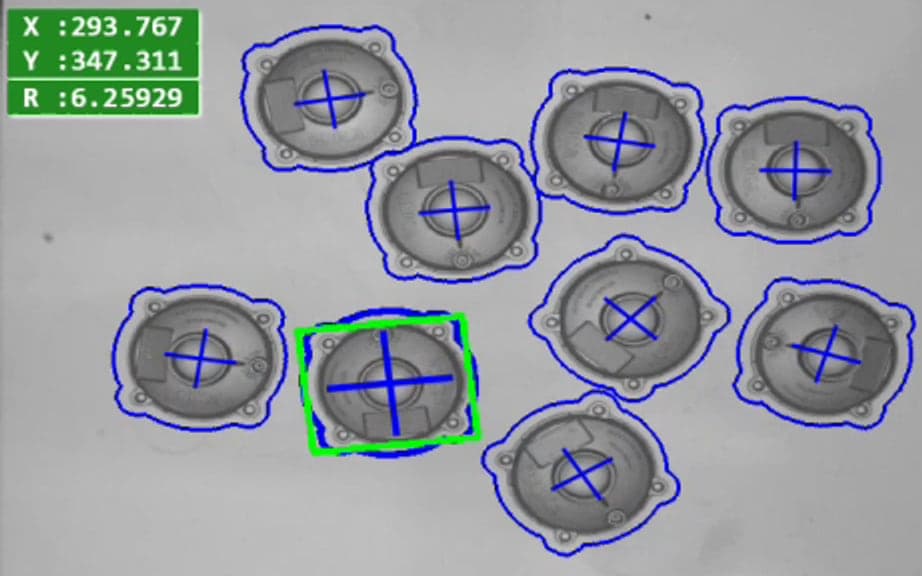
In classical robot applications the part has to wait at the same point and in the same orientation every time, which requires product-specific fixtures and feeders. Robot vision removes this constraint: the camera calculates the position and angle of parts arriving randomly on a conveyor or lying mixed in a bin, and the robot grips them accordingly.
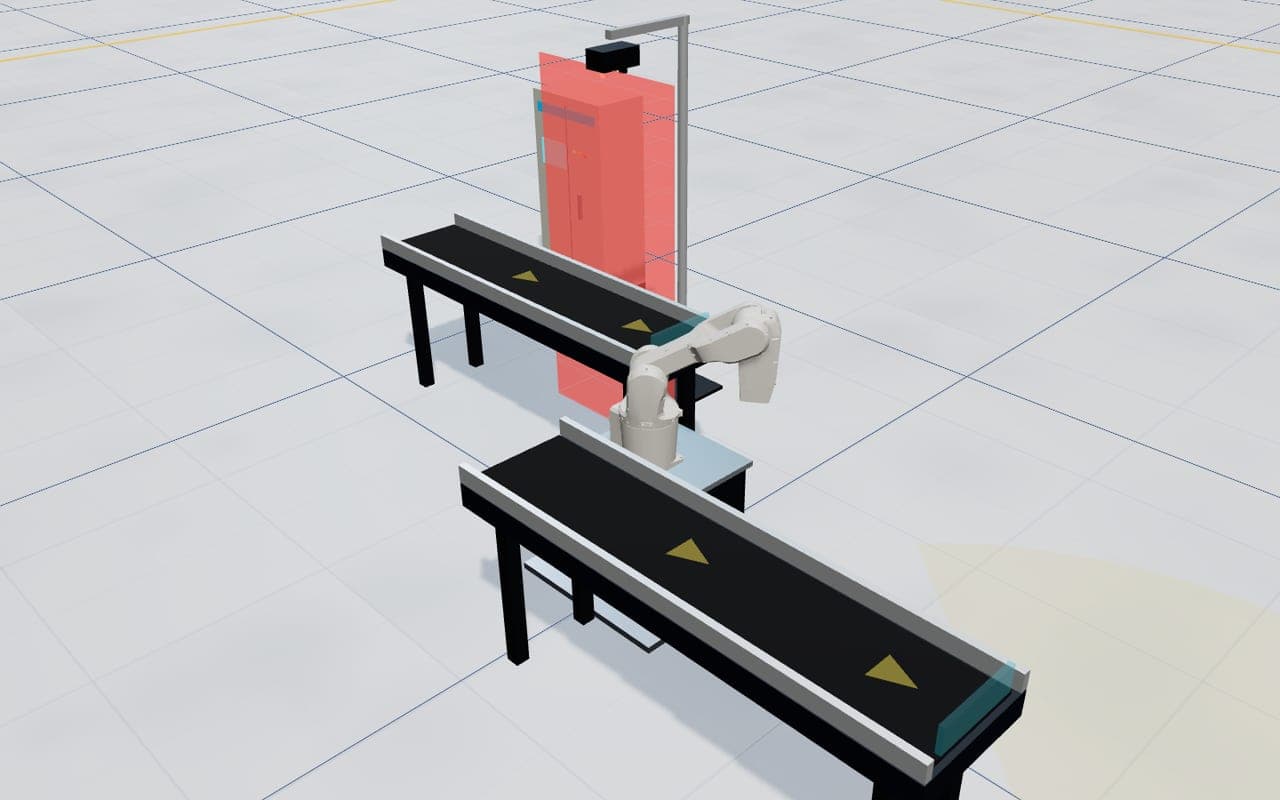
We have commissioned our vision systems with ABB, KUKA, FANUC and Nachi robots. Depending on the application, position and angle data is sent directly to the robot over TCP/IP or UDP, or via the PLC using the native protocols of different PLC brands. Hand-eye calibration converts the camera's pixel coordinates into the robot's coordinate system, and the camera can be mounted at a fixed point, on the robot arm or on a pneumatic mechanism.
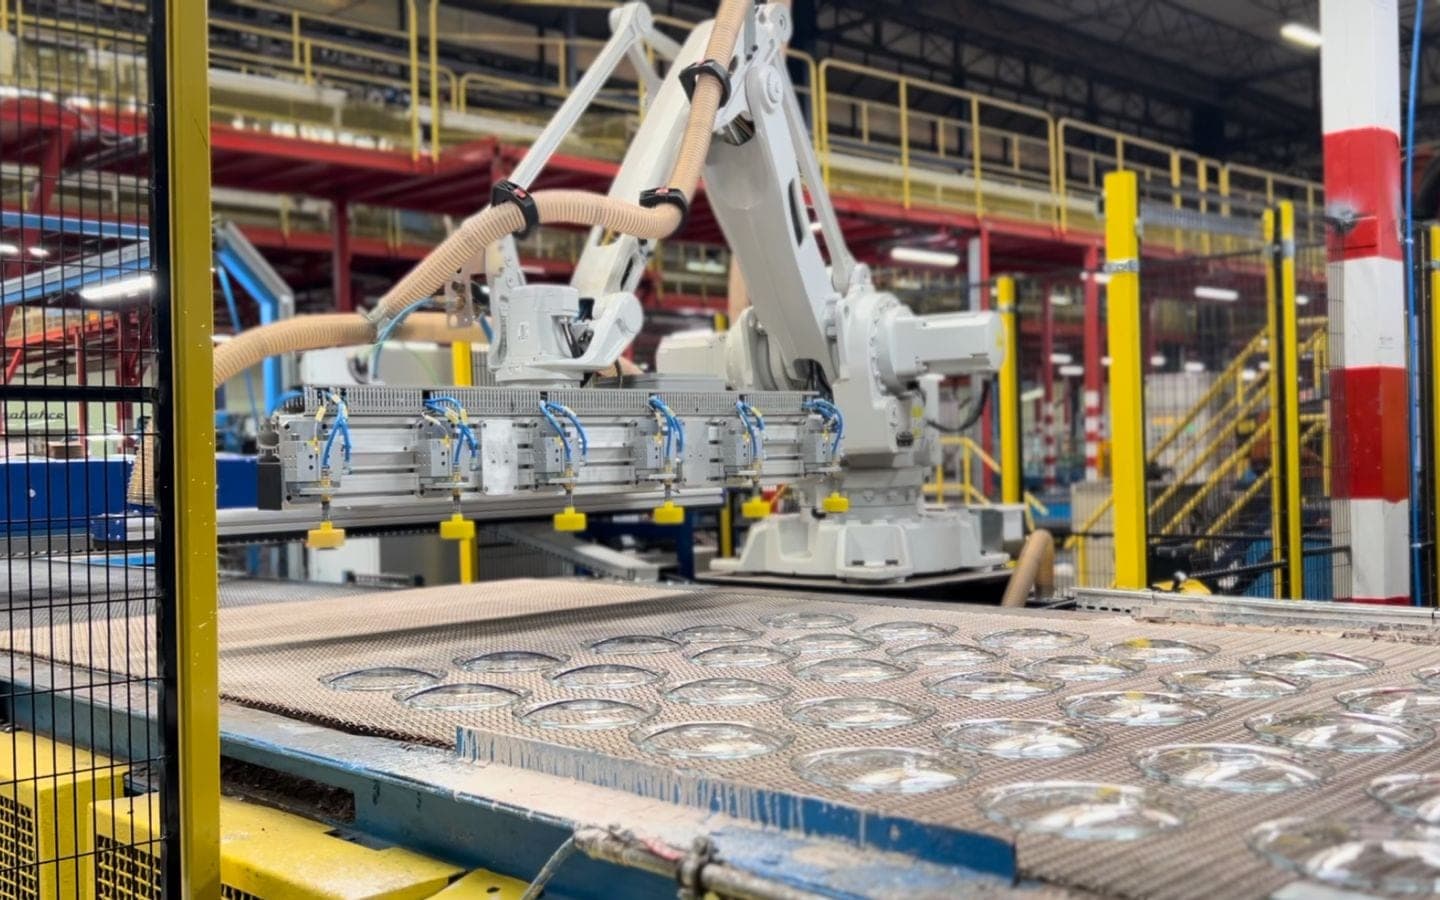
Some of our applications on the shop floor: picking over 100 types of glassware off a moving belt with conveyor tracking and sponge or vacuum grippers, picking randomly placed parts one by one by finding their position and angle, recognizing flange types and calculating the robot's target position, camera-based position correction in machine tending, and locating panel radiators on a conveyor with segmentation.
Highlights
- Random part picking
- ABB, KUKA, FANUC and Nachi integration
- TCP/IP, UDP and PLC protocols
- Camera fixed, on the robot or on a pneumatic mechanism
- Hand-eye calibration
- 2D and 3D camera options
Application areas
- Pick & place
- Machine tending
- Palletizing & stacking
- Glassware picking