Machine Vision
3D Vision
3D image processing produces point clouds with stereo, time-of-flight and laser-line cameras; 3D surface matching and measurement extend the scope of robotic applications.
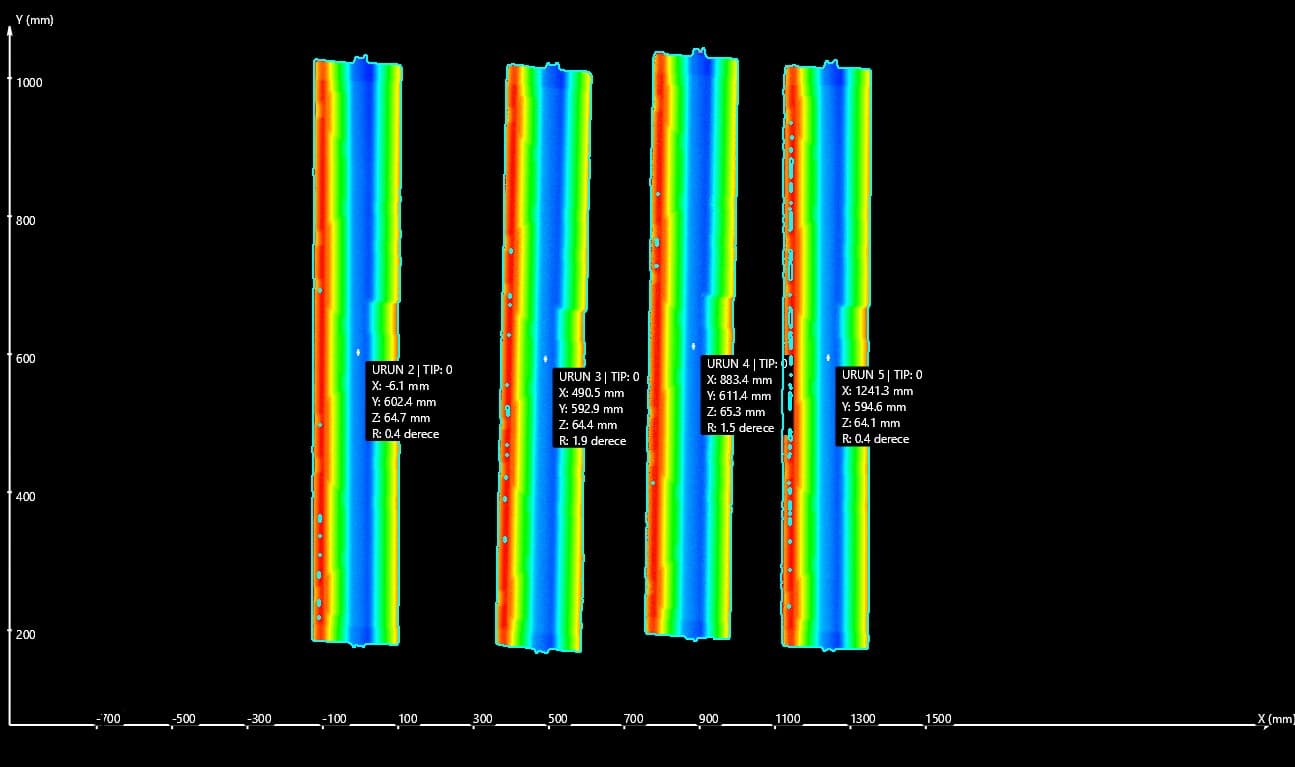
3D cameras are grouped by principle into stereo vision, time of flight and laser line (sheet of light). Whichever it is, a point cloud giving the real position of every pixel with its z-distance is obtained; measurement is done directly in real-world coordinates without the laborious calibration of 2D cameras.
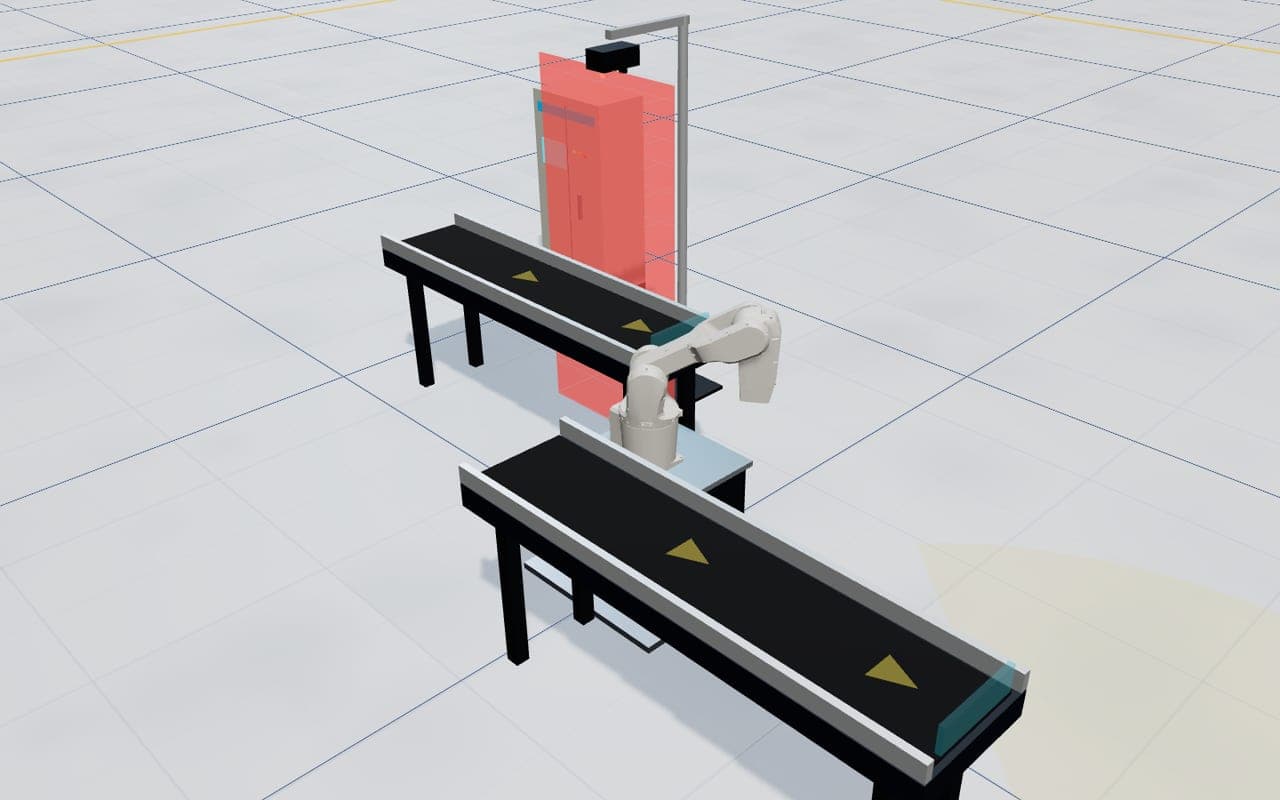
In 3D surface matching the part is taught from a CAD file or several images; parts arriving upright, lying, tilted or partially overlapping in a bin or on a conveyor are matched with all their surfaces. The grip point and rotation angle of each part are sent to the robot, which picks it and assembles it or drops it at the relevant station.
Real-world applications need further checks: whether the grip point can be reached by the gripper, whether its surroundings are clear. Good 3D software handles all of these; we develop project-specific software rather than relying on the limited functions of camera SDKs.
Highlights
- Stereo / ToF / laser line
- CAD-based surface matching
- Bin picking
- 3D measurement in real coordinates
Application areas
- Automotive castings
- Logistics depalletizing
- Metalworking
- Food (variable geometry)