Machine Vision
Matching / Part Location
Shape-based matching finds the reference part in the image, determines its position, angle and model, and passes the result to the robot or PLC.
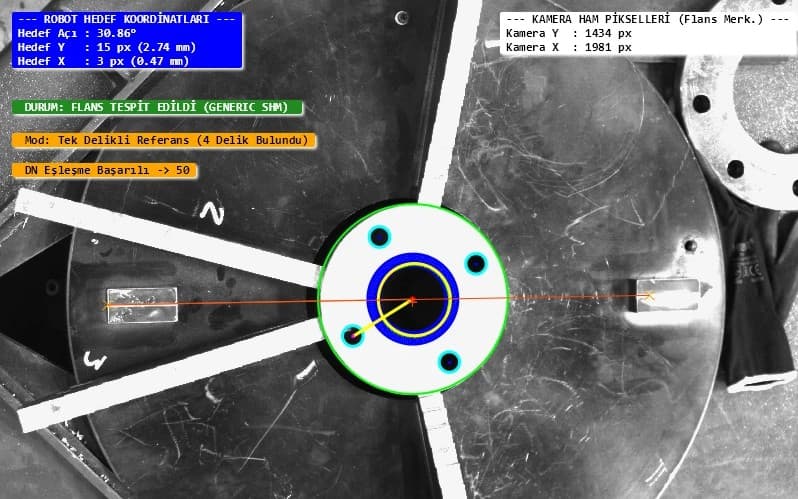
Matching is based on teaching the system the image of a reference part (golden sample) and searching for it in every subsequent image. It is a basic building block of most machine vision applications, including measurement, completeness checks, positioning, orientation and robot guidance.
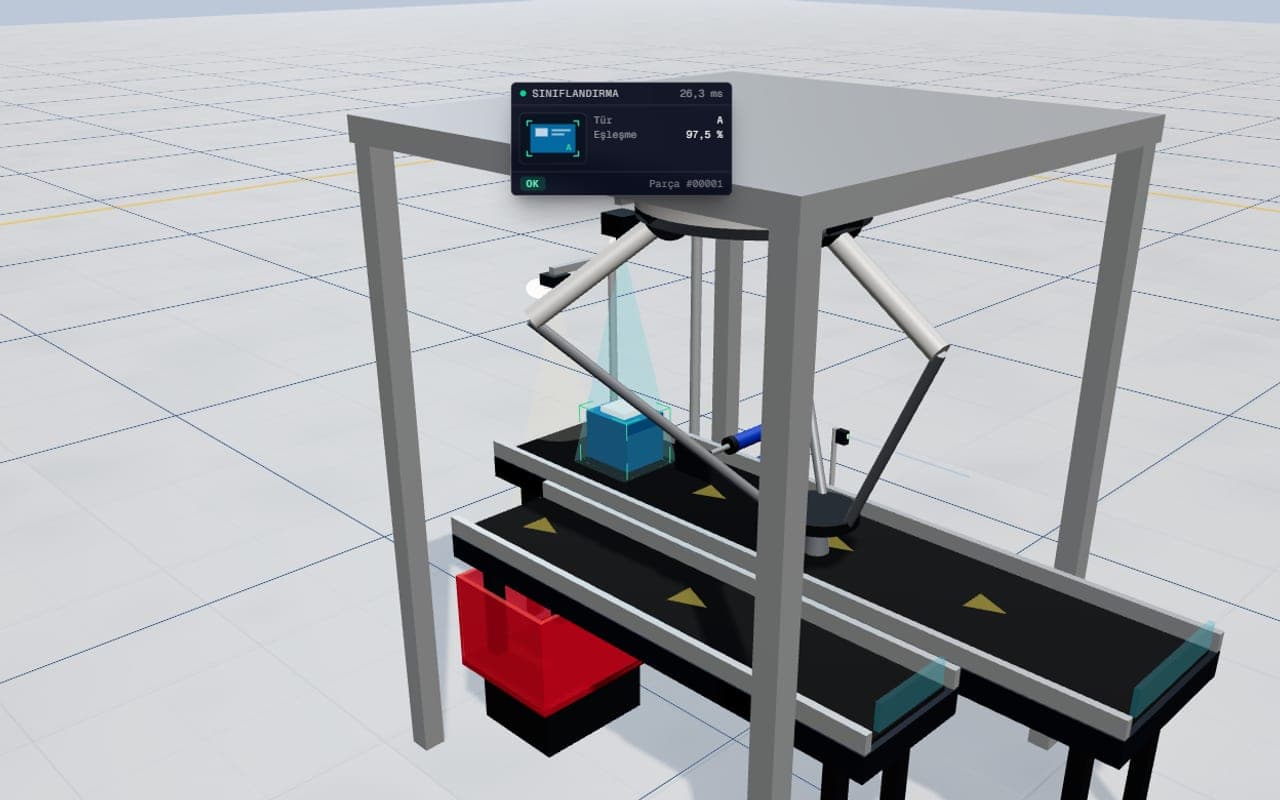
Shape-based matching works even when the part is rotated, scaled or partly covered. Depending on the application, the position and angle found are sent directly to the robot or to the PLC, and the match score shows whether the part is the right model. We develop the software tailor-made for each application's part and station.
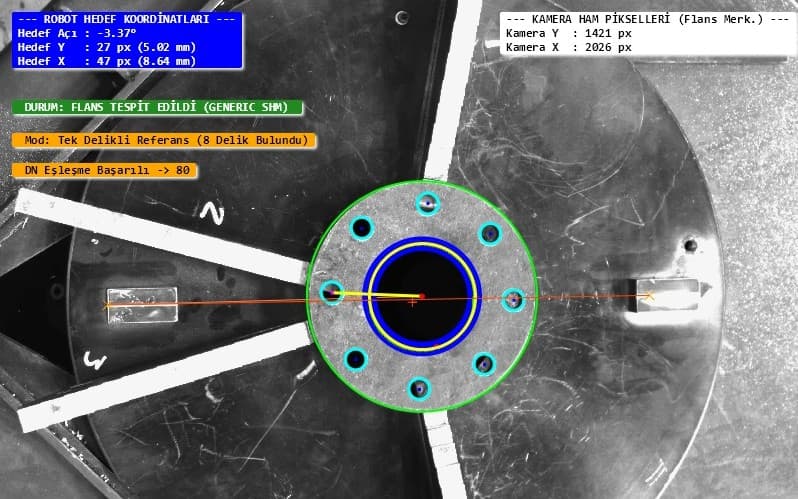
An example from the field: in our flange recognition application, the type of flanges of different diameters (DN50, DN80…) is identified by shape matching; once the center and bolt holes are found, the robot's target position and angle are calculated with millimeter precision. The image on this page is the screen of this application.
Highlights
- Robust to rotation and scale changes
- Model and variant verification
- Position and orientation finding
- Results straight to the robot or PLC
- Software tailored to each customer
Application areas
- Metalworking
- Automotive
- Packaging
- Electronics