The challenge
Flanges of different sizes arrived at the station in different positions and orientations. For the robot to approach each flange at the right point and angle, the flange type, center and rotation had to be known every time.
Our solution
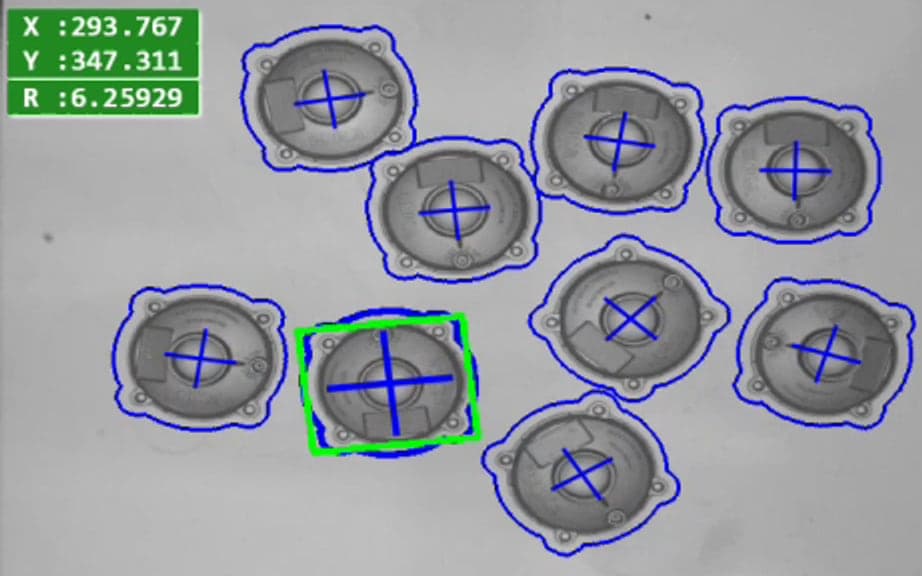
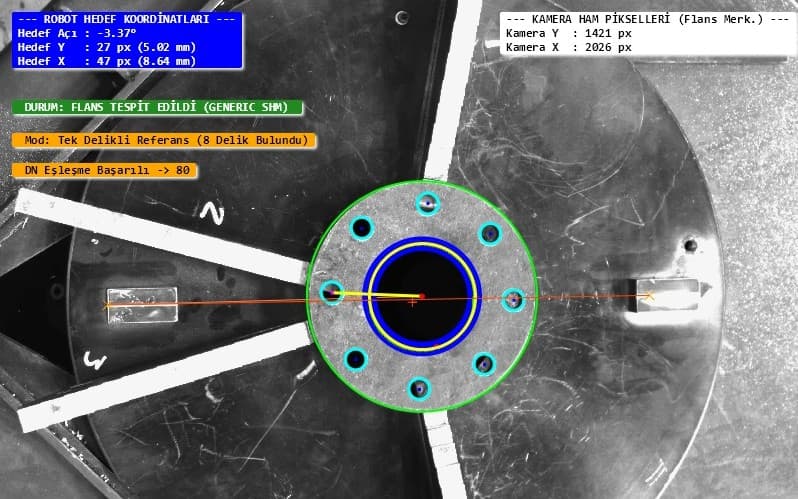
Shape-based matching on the camera image identifies the flange type (DN50, DN80…), after which the center and bolt holes are detected. The flange's rotation is calculated from the position of a single reference hole.
Pixel coordinates are converted to millimeters through calibration, and the robot's target angle and X–Y correction are sent to the robot with millimeter precision. The screens below show a 4-hole DN50 and an 8-hole DN80 flange being recognized.