The challenge
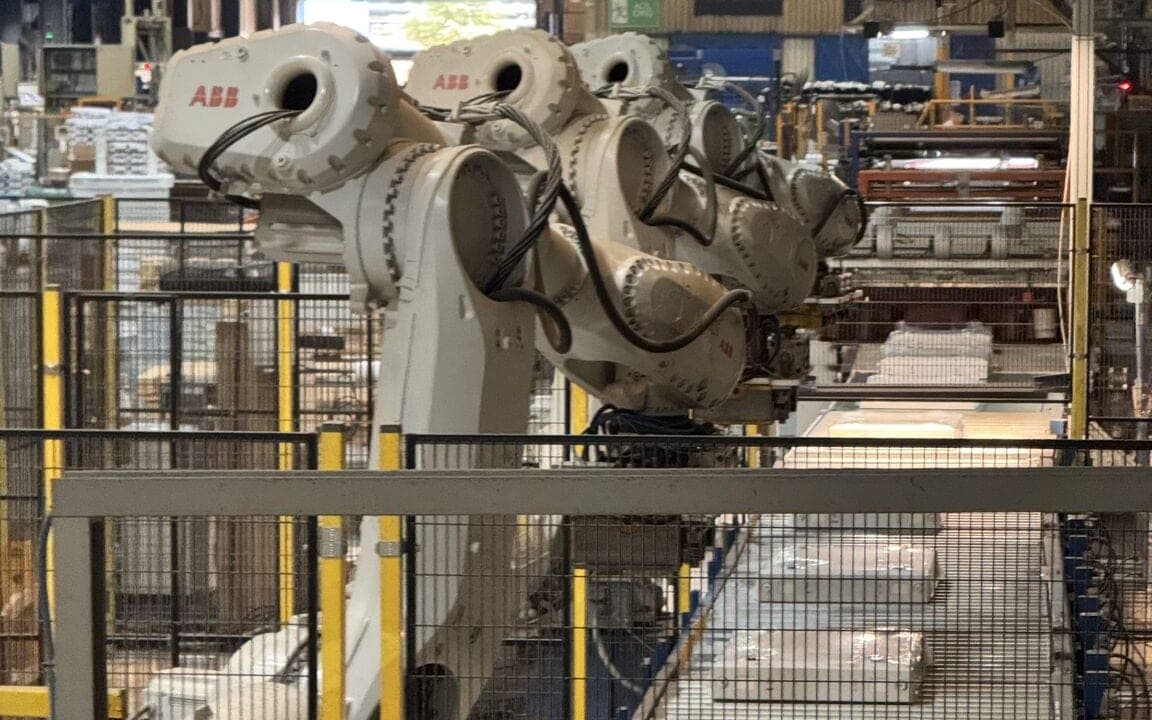
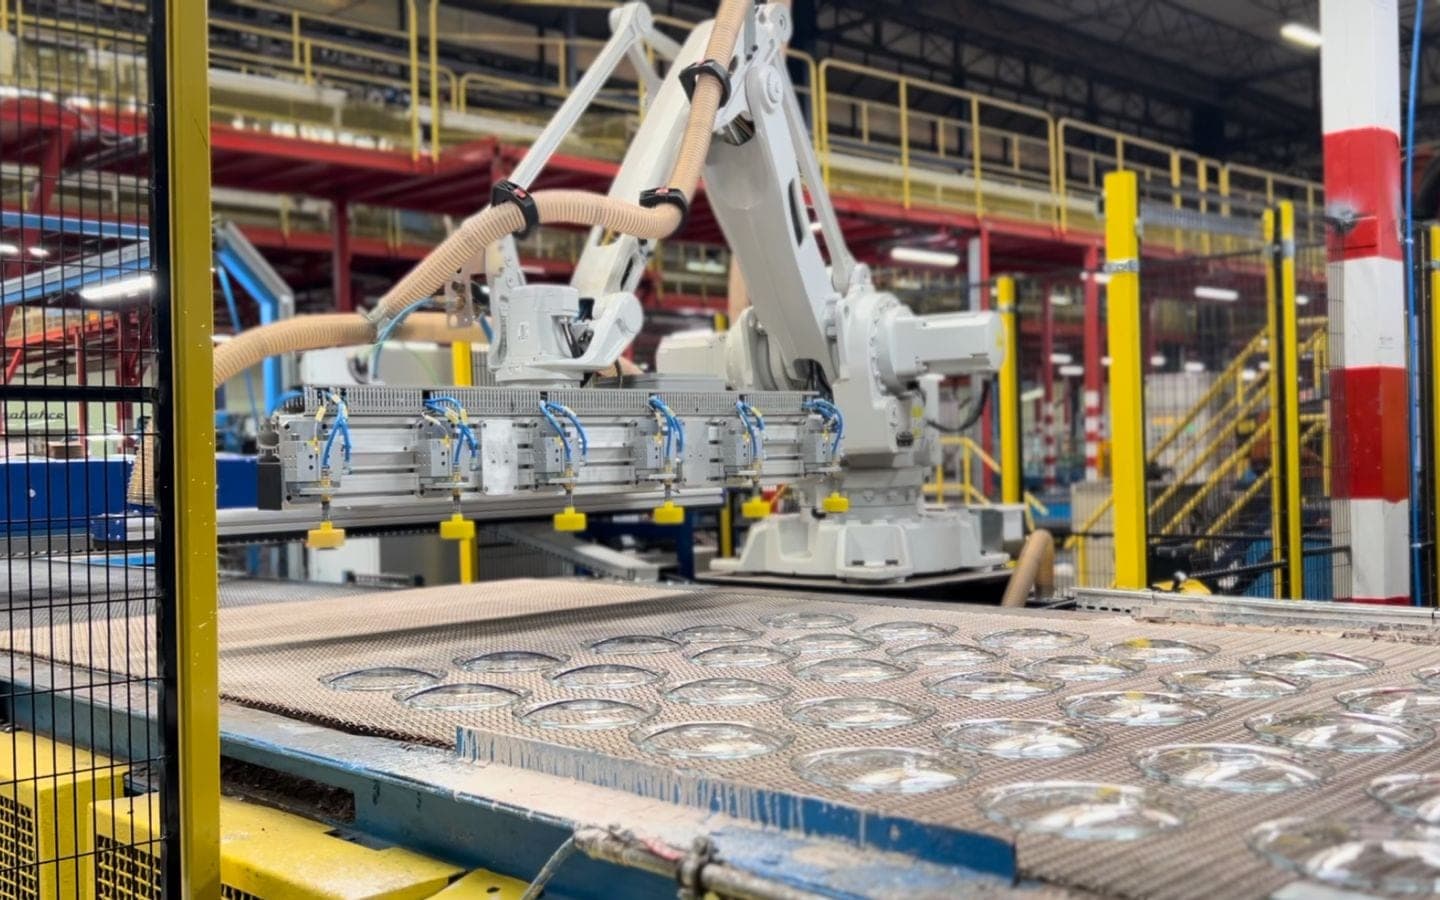
Parts dropped in the work area at random positions and angles had to be picked one by one by the robot, without a dedicated fixture for each part.
Our solution
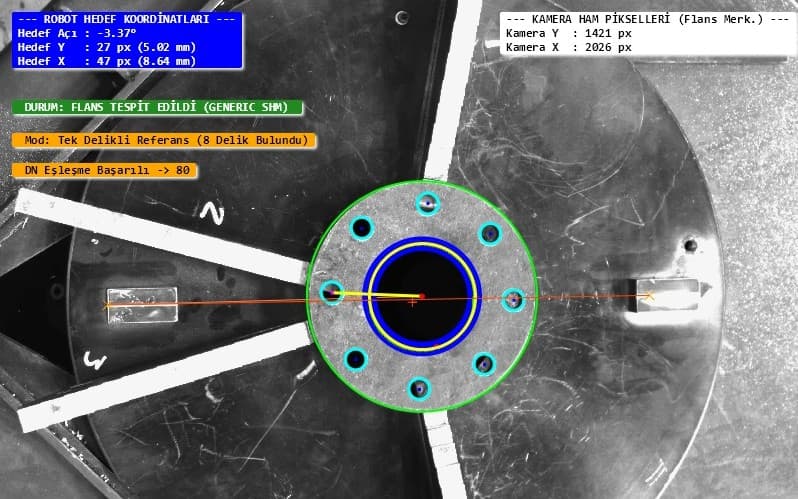
The camera images the work area; our software finds the contour of each part and calculates its center and rotation. The X–Y position and angle of the part to be picked are sent to the robot, which grips the part accordingly.
The operator interface shows inspection counts, statistics and the image of each position; the product to be run is selected from a recipe.