Our solution
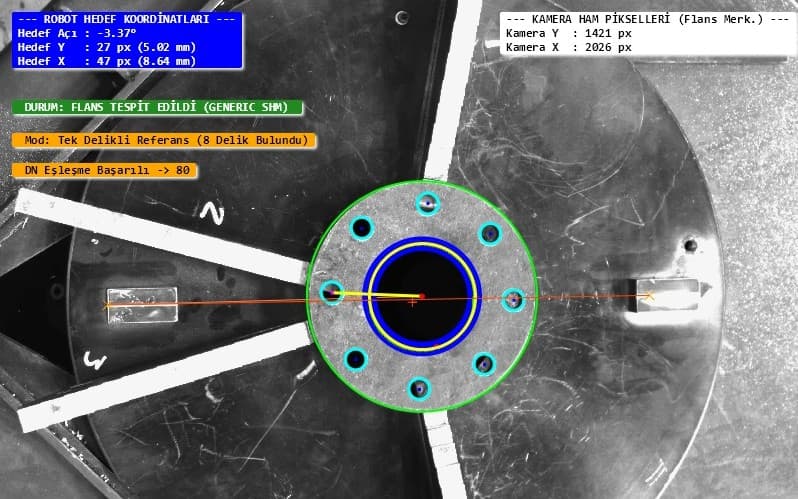
The camera images the parts in the work area; our software finds the contour of each part and calculates its centre and rotation. The X and Y position and the angle of the part to be picked are sent to the robot.
The interface shows control counts, statistics and the image of each position; the product is selected from a recipe.