The challenge
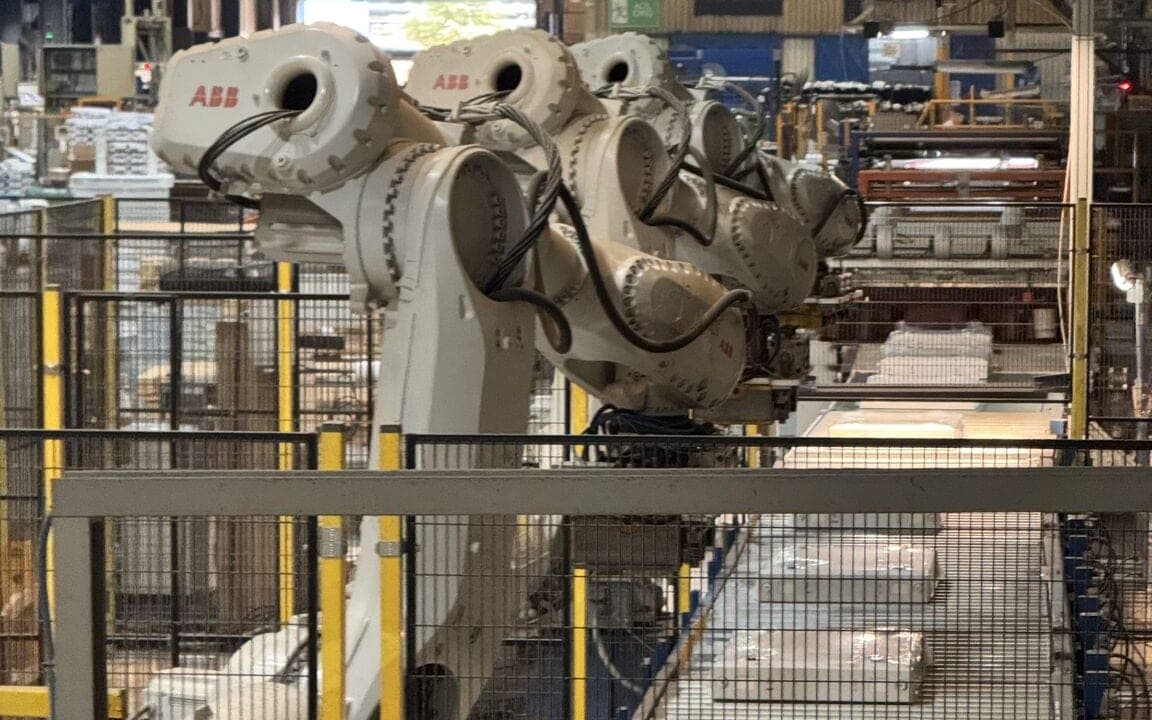
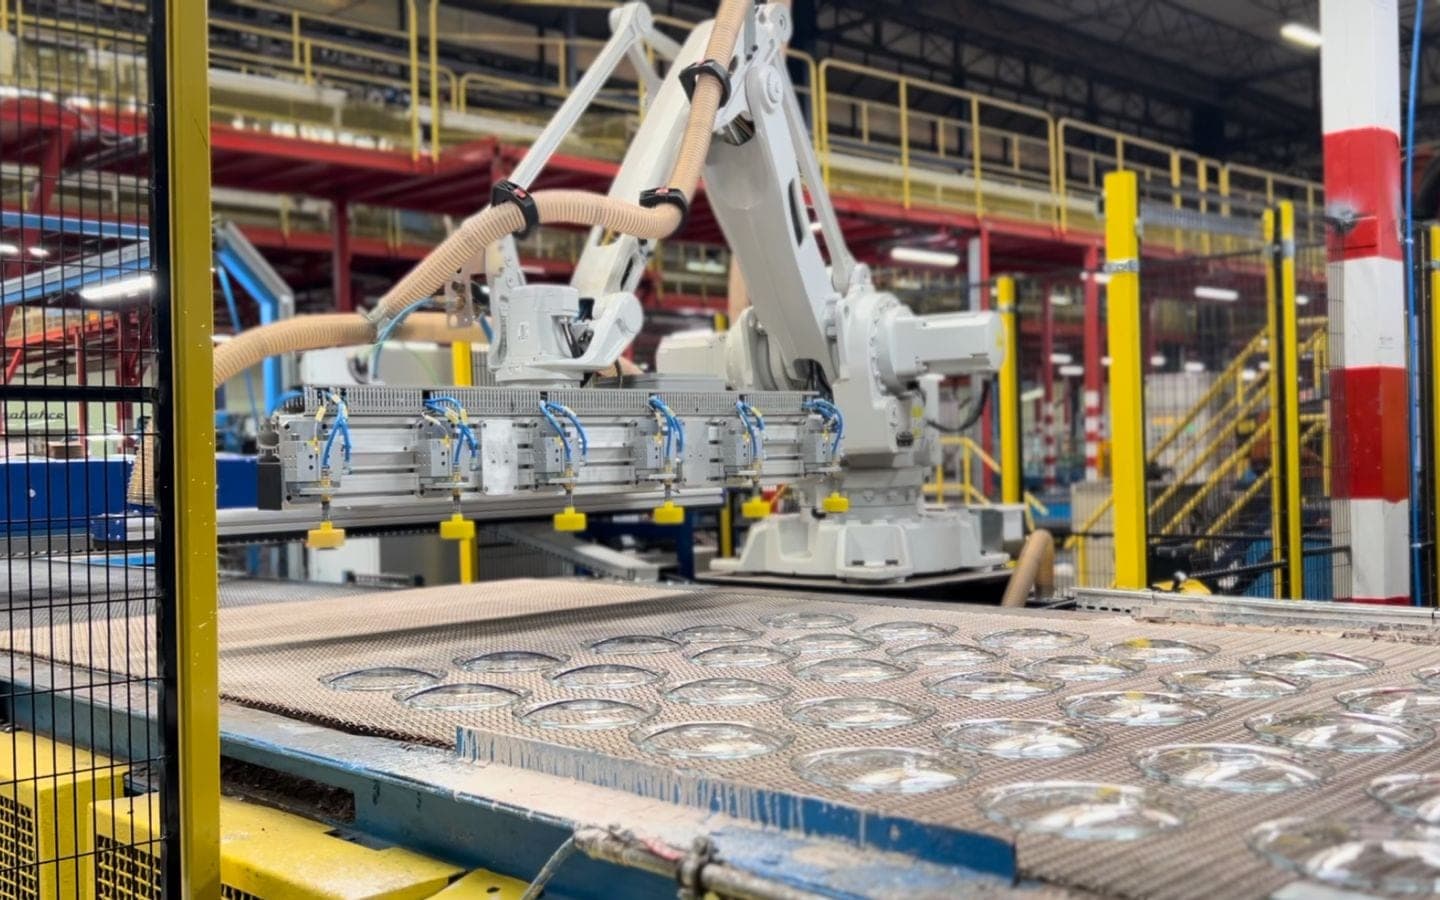
Parts had to be placed in the processing station at the right position and angle every time, which meant measuring small position and angle deviations on each part before the robot moved.
Our solution
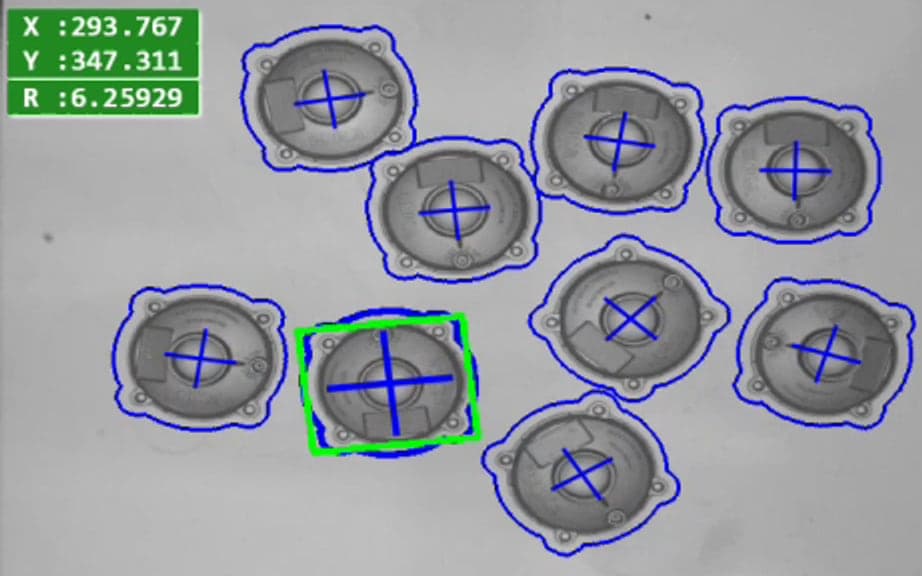
The camera locates the pin and a second reference feature on the part, calculates the position deviation in X and Y in millimeters and the rotation in degrees, and sends them to the robot, which applies the correction to its motion.
The product being run is selected on screen; robot commands, logs and product settings are managed from separate tabs of the interface.