Machine Vision
3D Vision
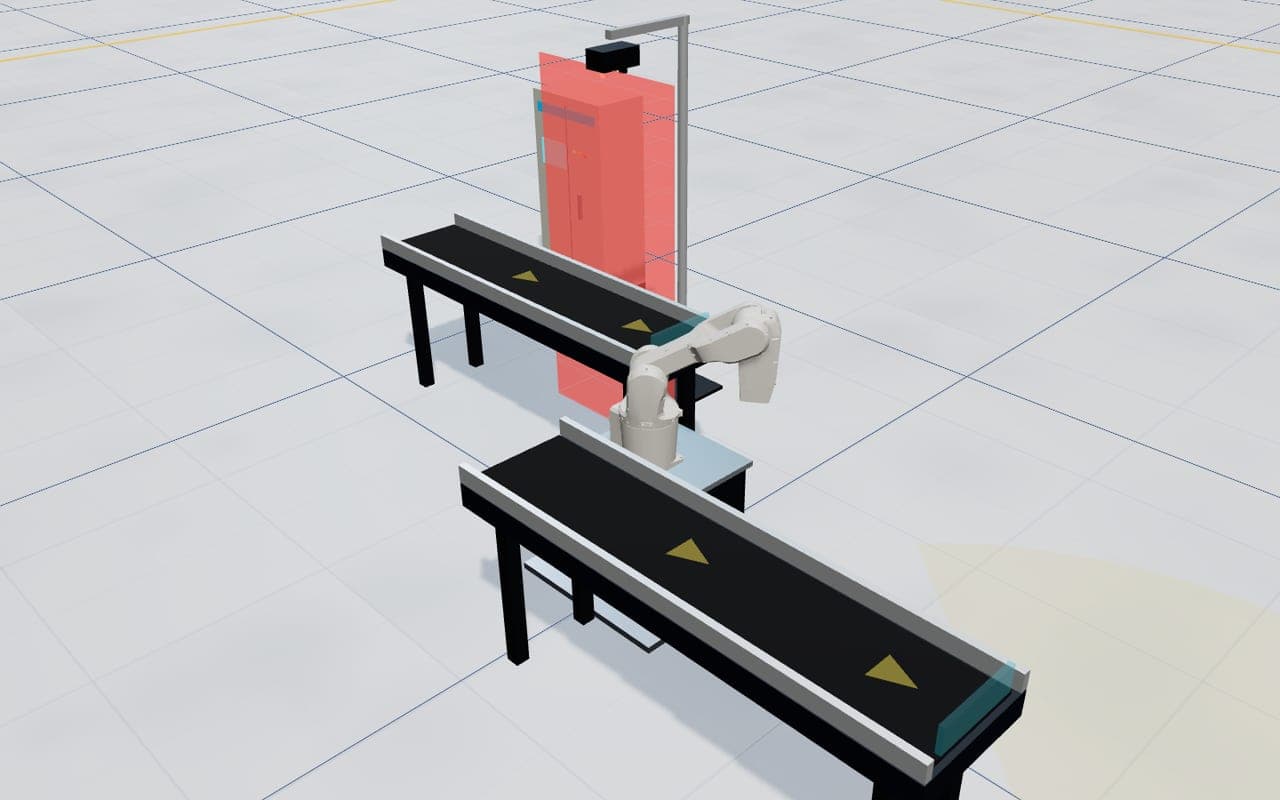
We build a 3D image of products with laser profile sensors, find each product's type, position, height and rotation, and determine where the robot picks it.
3D machine vision gives the real position of every point of an object with laser profile, stereo or time-of-flight (ToF) cameras, so products that overlap, differ in height or lie irregularly are found reliably even where a 2D camera cannot tell them apart.
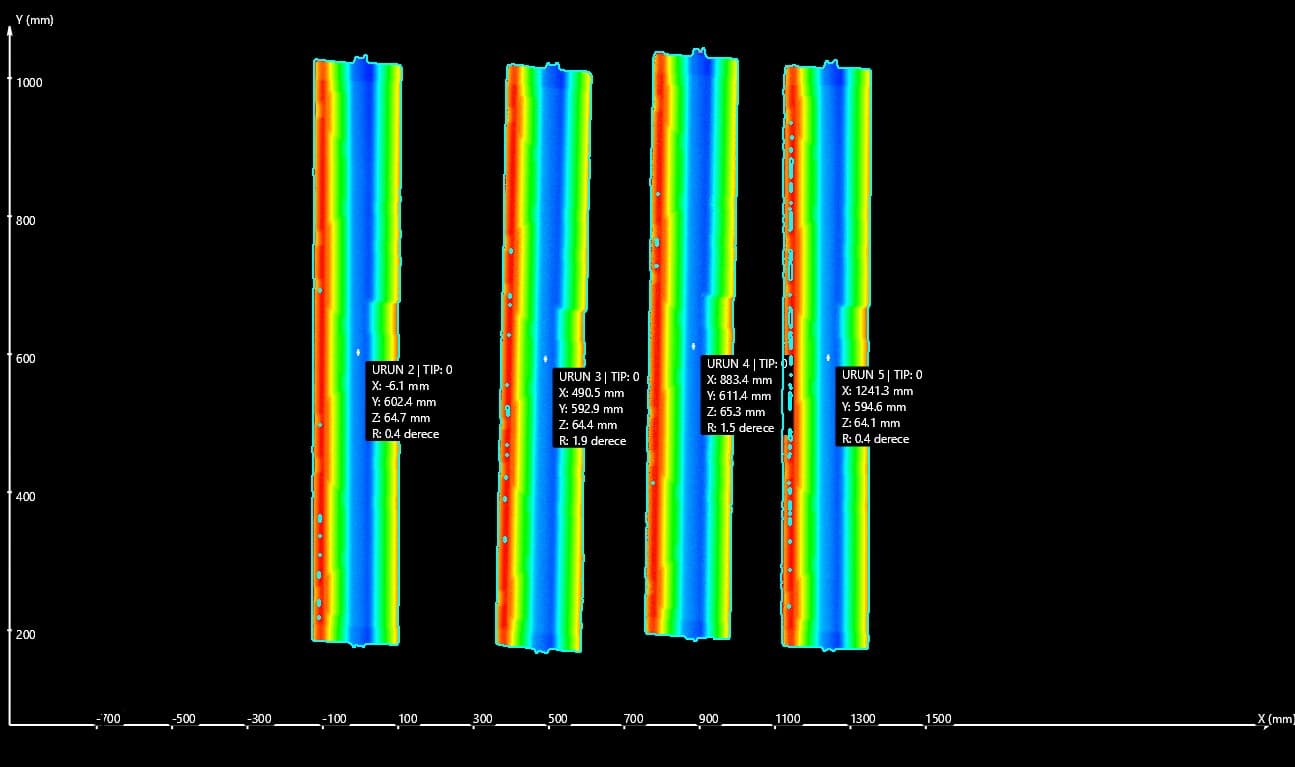
In our 3D application different products arrive on a conveyor. Two LMI Gocator 2490 laser profile sensors scan the line, and their data is merged into a single height map. A deep learning model finds each product in this image and identifies its type; our software calculates the product's center of gravity, height and rotation and writes the values in millimeters directly to the Siemens PLC over the S7 protocol (S7.Net). Using this data, the robots stack each product at the station assigned to its type, on top of the same products.
The application runs on our own C#-based machine vision software: sensor data acquisition, product separation, measurement and PLC communication are managed from one interface. The image on this page shows each product's X, Y, Z position and rotation on the height map. The same foundation applies to height and volume measurement, CAD-based 3D matching and bin picking.
Highlights
- One 3D image from two LMI Gocator 2490 sensors
- Product type recognition with deep learning
- Center of gravity, height and angle in mm
- Direct Siemens PLC communication via S7.Net
- Stacking by product type at dedicated stations
- Our own C# machine vision software
Application areas
- Mixed product sorting and stacking
- Palletizing & depalletizing
- Height & volume measurement
- Bin picking